Chrystal Chern

Research Engineer, R&D at Gridware.

prof_pic.jpg

945 Front St

San Francisco, CA 94111

I am a dynamics researcher working at the intersection of mechanical modeling, sensing, and scientific computing. My research centers on system identification: extracting models of physical systems from measured data, understanding when those models can and cannot be trusted, and using them to detect anomalies in physical behavior. My current work applies this research to asset management of critical infrastructure such as the power grid.

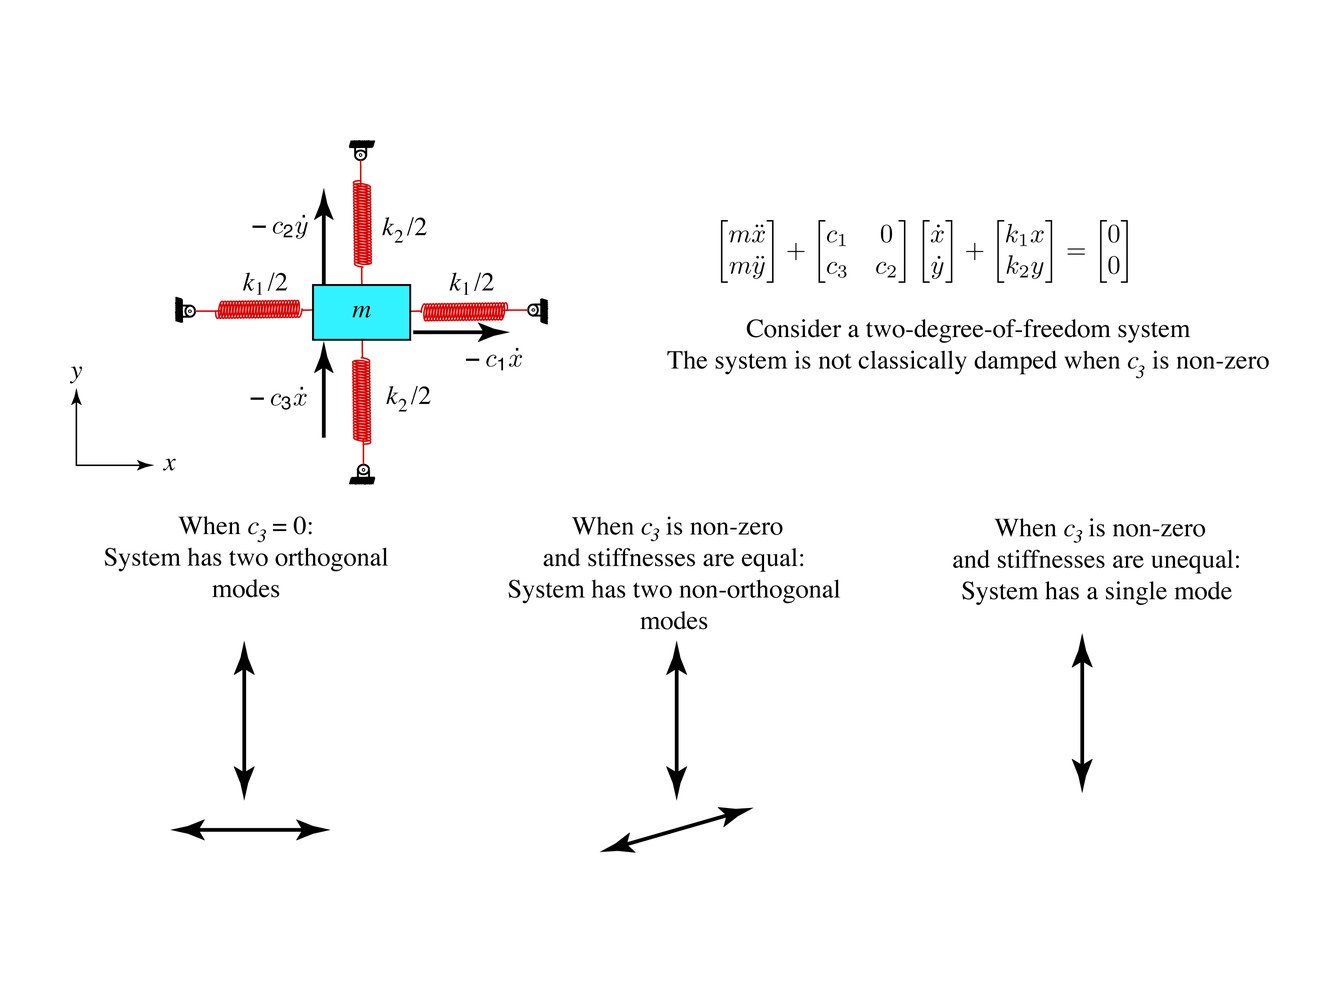
Previously at UC Berkeley, I developed a digital twin framework for monitoring the health of civil infrastructure from vibration data. Mechanical models included finite element analysis and system identification. Further dynamics research covered the causal structure of coupled human–object motion from multi-node IMU sensor networks, resolving ambiguity in the modal analysis of damped mechanical systems, and building open-source Python tools for system identification at scale.
selected publications

  1. ASME JAM
    single-surviving-mode.jpg
    On Complex Modal Inverse Analysis: The Cautionary Tale of the Single Surviving Mode
    Chrystal Chern and Oliver M. O’Reilly
    Journal of Applied Mechanics, 2026
  2. Nonlin. Dyn.
    The Symphony of Gyrations Producing Steady Motions of a Hula Hoop: Insights from a Network Analysis
    Chrystal Chern, Theresa E. Honein, and Oliver M. O’Reilly
    Nonlinear Dynamics, 2026
  3. JBE
    Human-Machine Collaboration Framework for Bridge Health Monitoring
    Sifat Muin, Chrystal Chern, and Khalid M. Mosalam
    Journal of Bridge Engineering, 2024
  4. EVACES
    Structural Response Prediction from Learned System Realization Matrices
    Chrystal Chern, Claudio Perez, and Khalid M. Mosalam
    In 11th International Conference on Experimental Vibration Analysis of Civil Engineering Structures (EVACES), 2025
  5. Software
    mdof: An Open-Source Python Package for System Identification
    Chrystal Chern, Claudio Perez, and Khalid M. Mosalam
    2024